REMM: Revisable Embodied Memory for Manipulation
Authors: Revanth Krishna Senthilkumaran, Ruwan Wickramarachchi, Alessandro Oltramari, Jonathan Francis
Status: Preprint 2026
M.S. Robotics, Carnegie Mellon University
Robot Learning Intern, Bosch Center for AI
I build robot learning systems that reason about physical interaction and transfer manipulation skills across embodiments, tasks, and environments.
My goal is to develop general-purpose manipulation policies that combine perception, reasoning, and action—and can reuse knowledge across different robot bodies rather than learning every skill from scratch.
currently
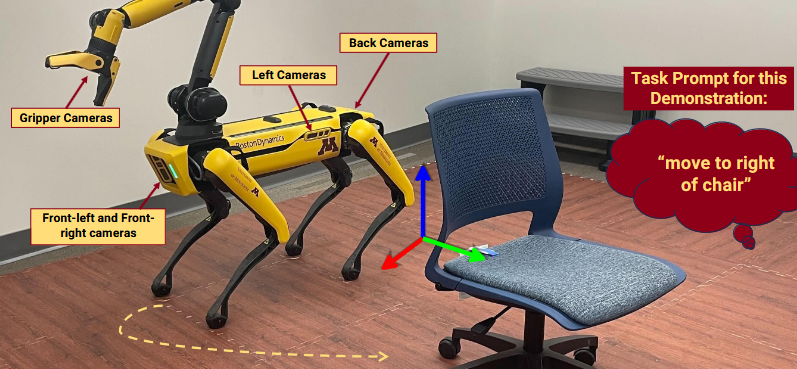
At CMU and the Bosch Center for AI, I study embodied reasoning and cross-embodiment robot learning, co-advised by Dr. Jonathan Francis and Prof. Ding Zhao. I am especially interested in how demonstrations, video, and interaction data can help robots acquire manipulation skills that generalize.
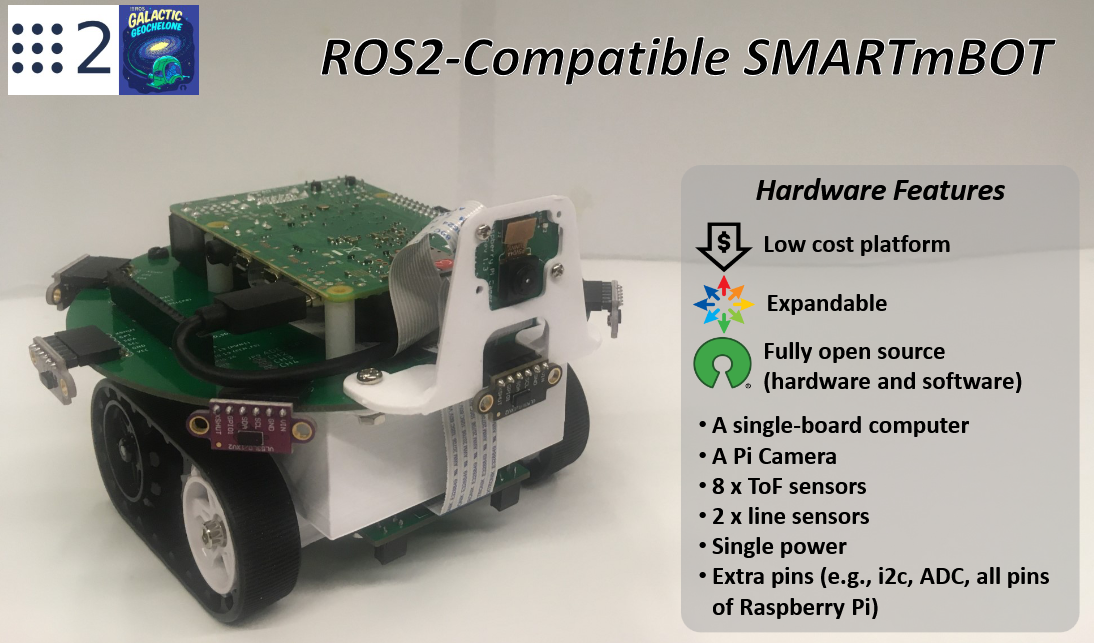
Background: Before CMU, I earned a B.S. in Computer Engineering from Purdue and completed internships at AeroVironment as a Robotics Software Engineer and at Prof. Karthik Desingh's Robotics Perception and Manipulation Lab (RPM Lab) at the University of Minnesota. I also conducted research at Purdue's SMART Lab with Prof. Byung-Cheol Min, IDEAS Lab with Prof. Aniket Bera, and the Air Force Research Laboratory with Prof. James Goppert. Outside research, I play piano and love playing and watching sports (check out BallTalk). Every week, I also try finding new food and coffee spots in town!
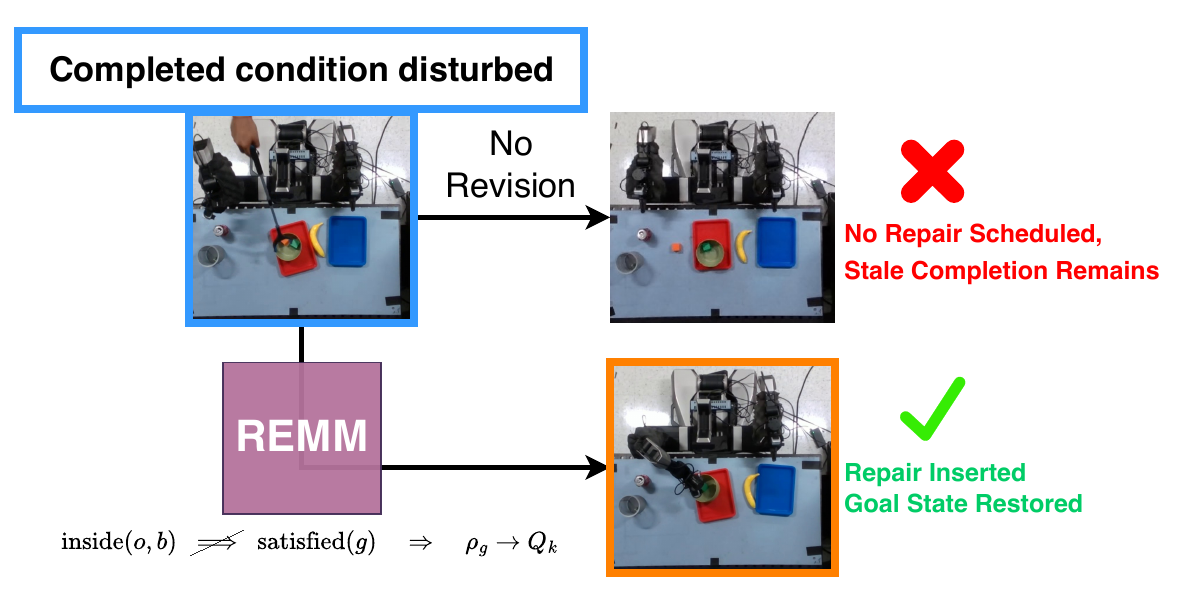
Authors: Revanth Krishna Senthilkumaran, Ruwan Wickramarachchi, Alessandro Oltramari, Jonathan Francis
Status: Preprint 2026
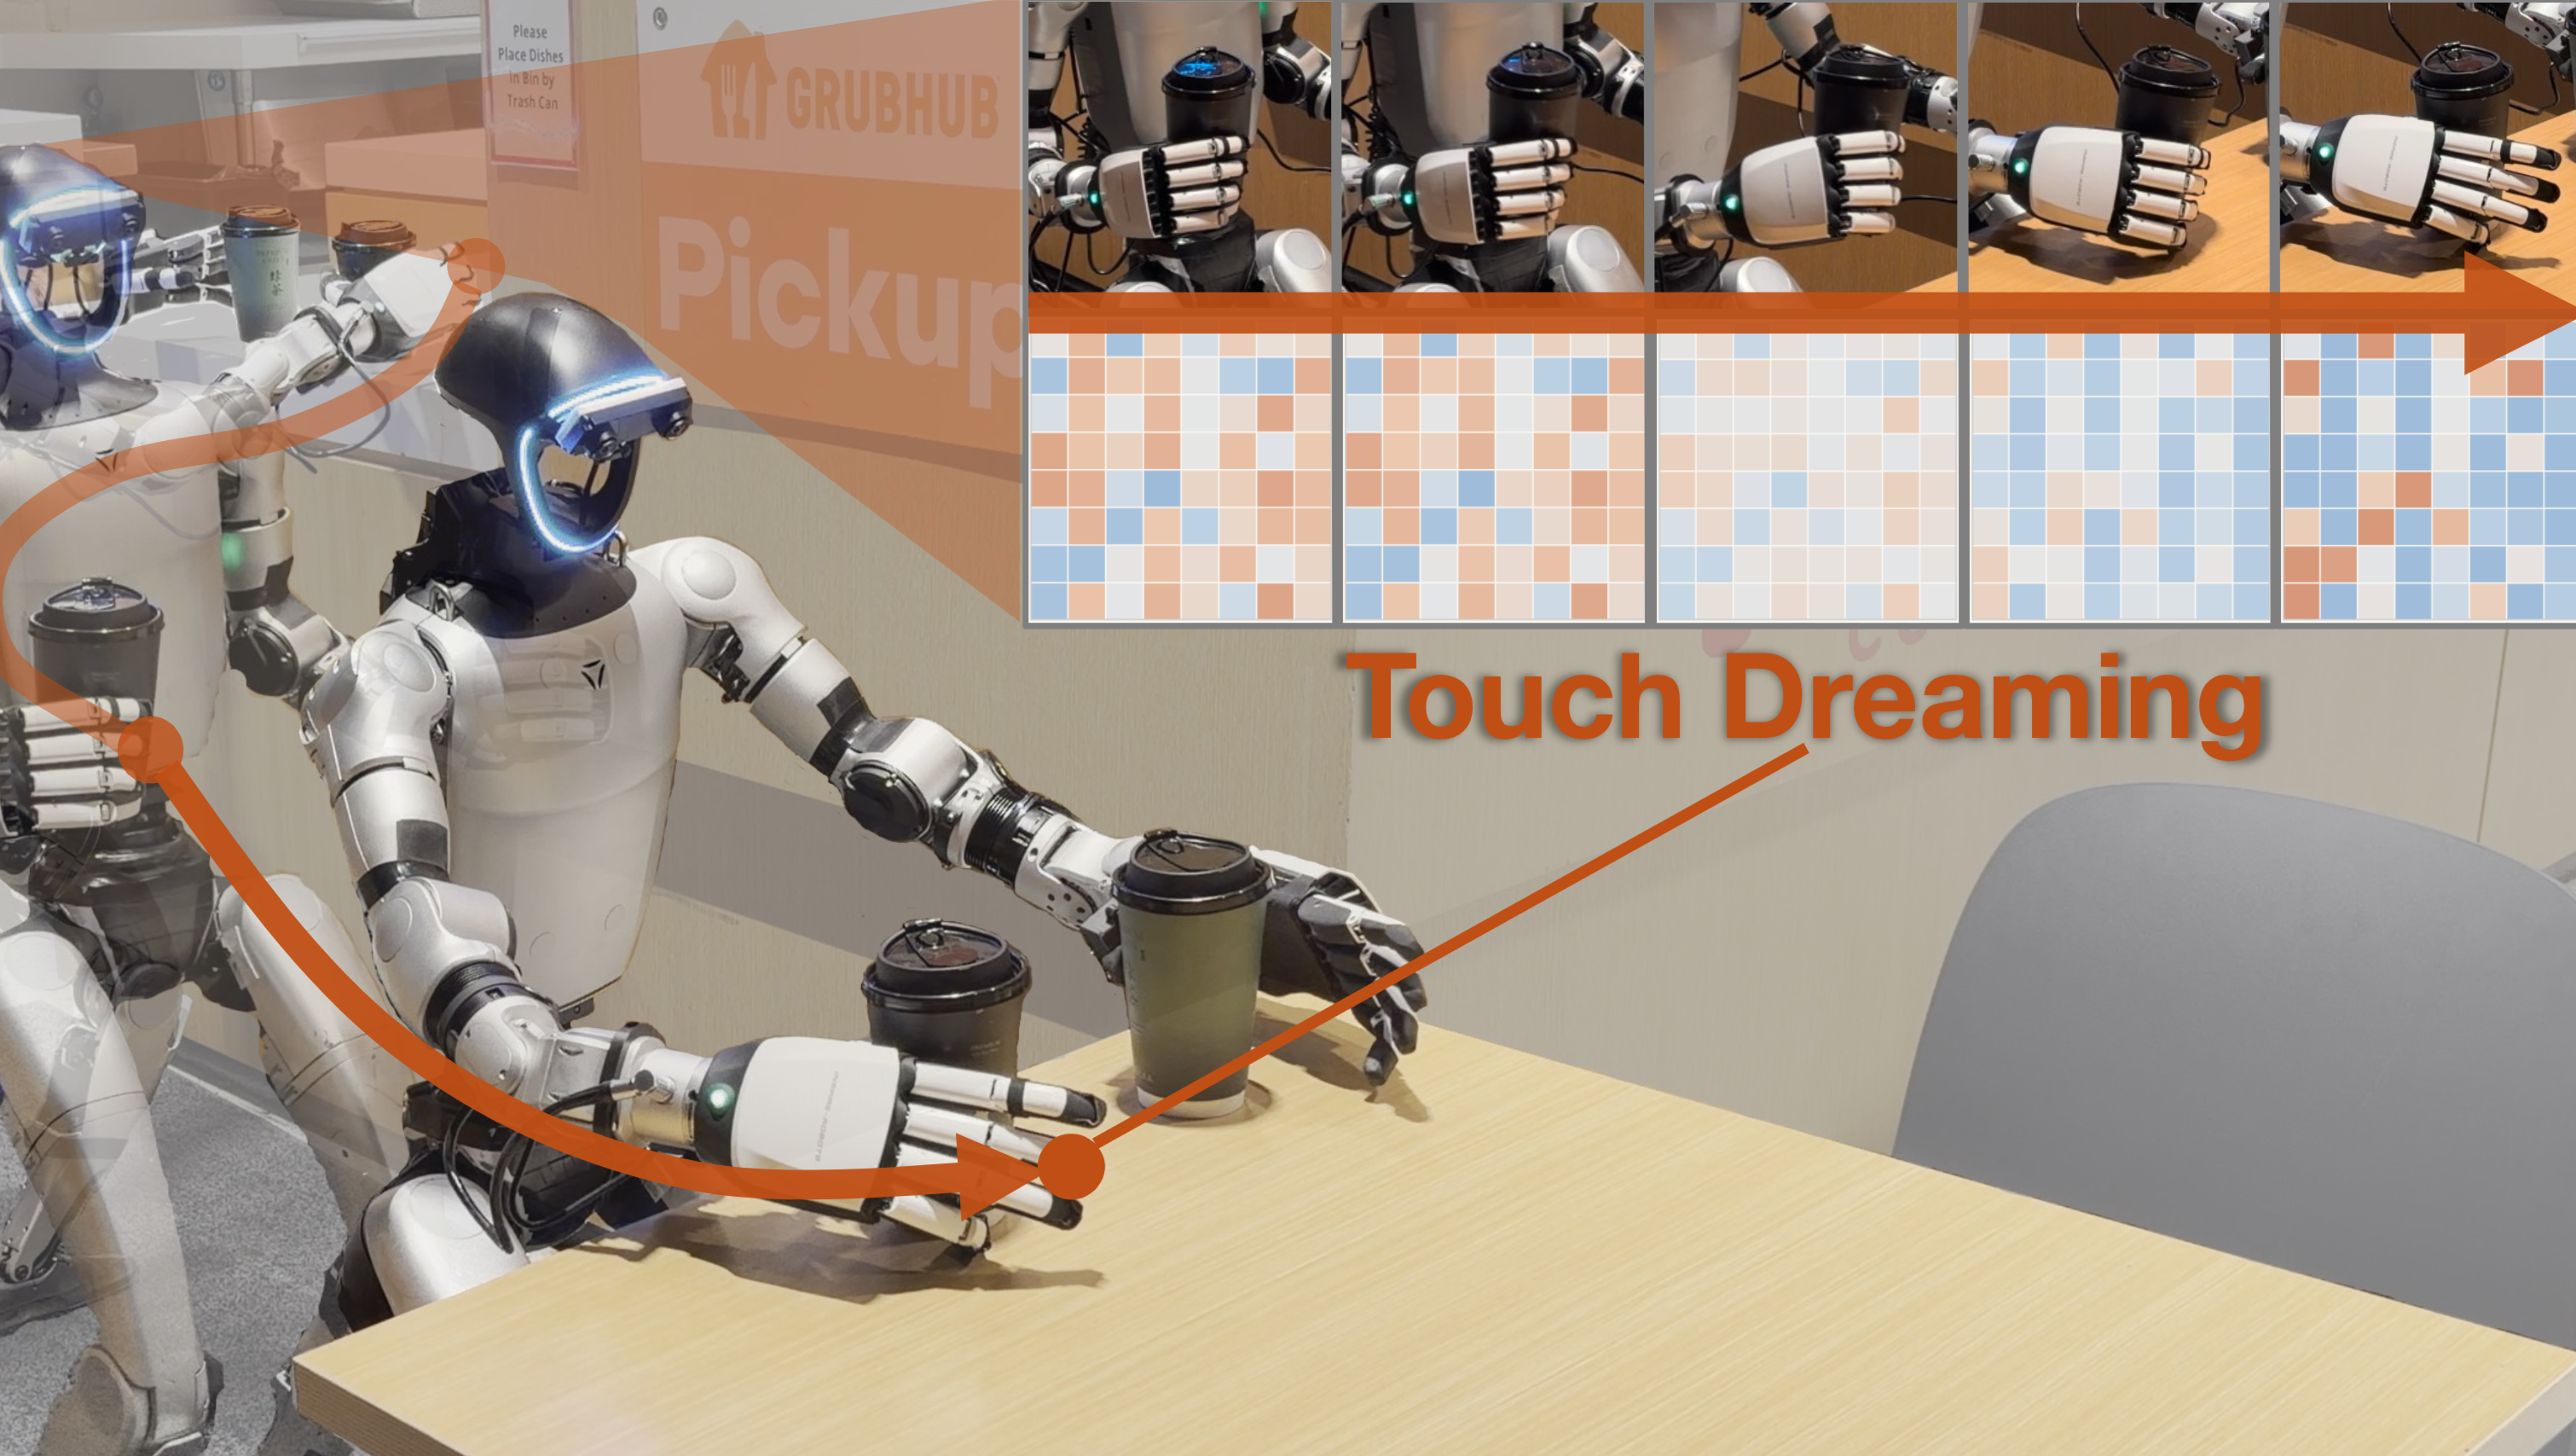
Authors: Yaru Niu, Zhenlong Fang, Binghong Chen, Shuai Zhou, Revanth K. Senthilkumaran, Hao Zhang, Bingqing Chen, Chen Qiu, H. Eric Tseng, Jonathan Francis, Ding Zhao
Status: IEEE-IROS 2026, RSS WCBM Workshop 2026 (ORAL), RSS SemRob Workshop 2026, RSS Tactile for FM Workshop 2026
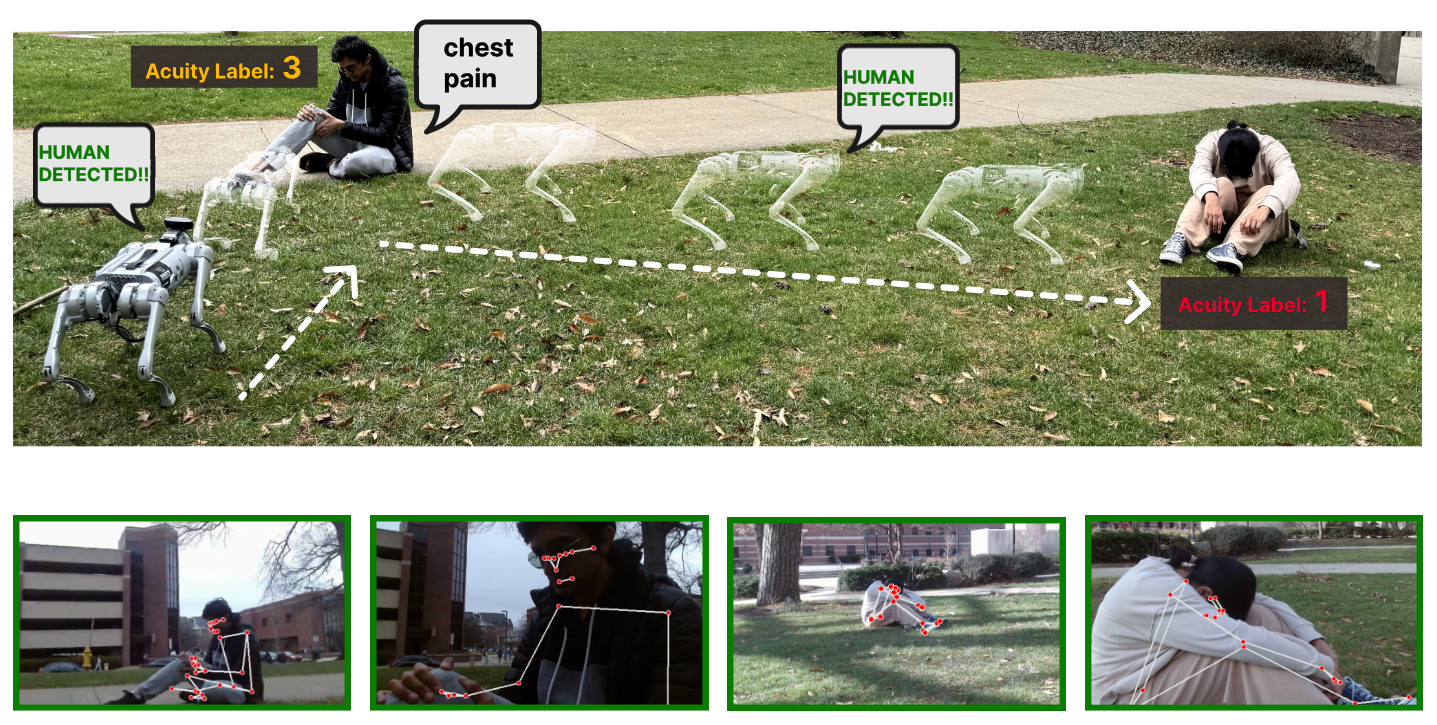
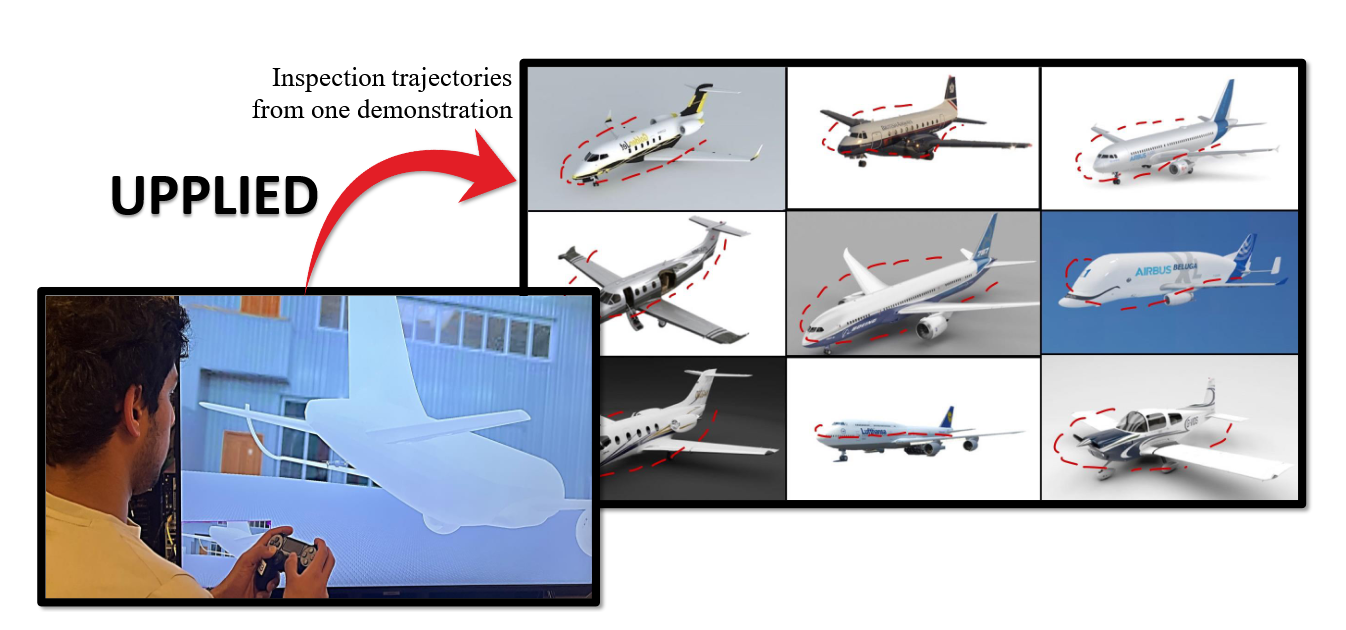
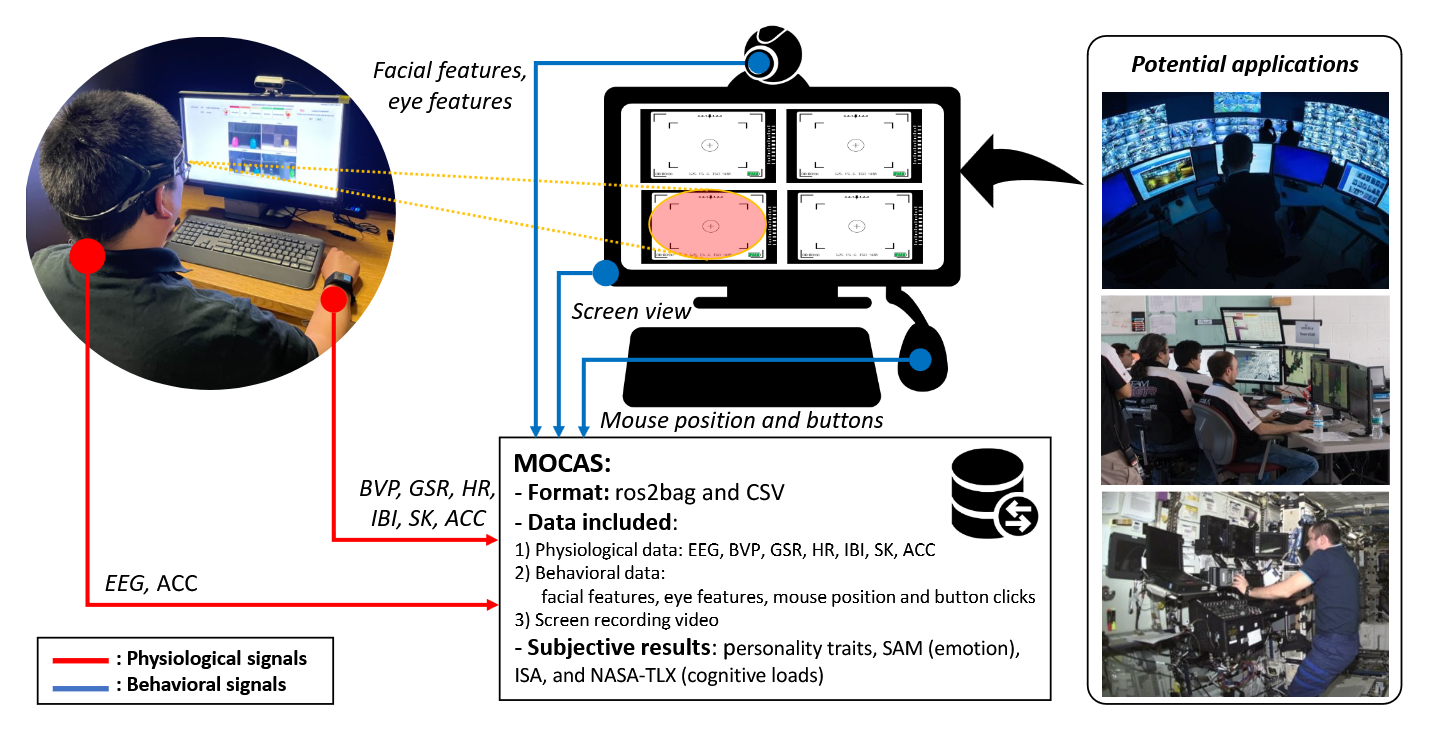
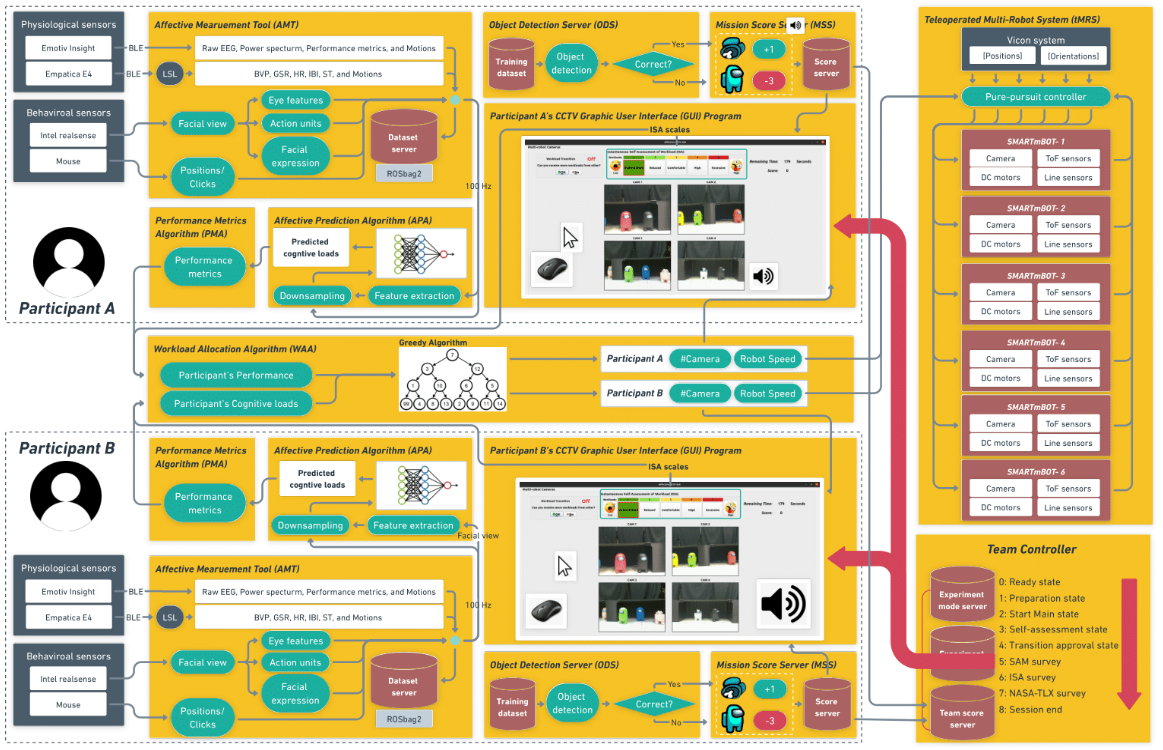
Venue: Purdue Spring URC 2023